Livox Mid-360S 3D LiDAR Sensor – Successor to Mid-360
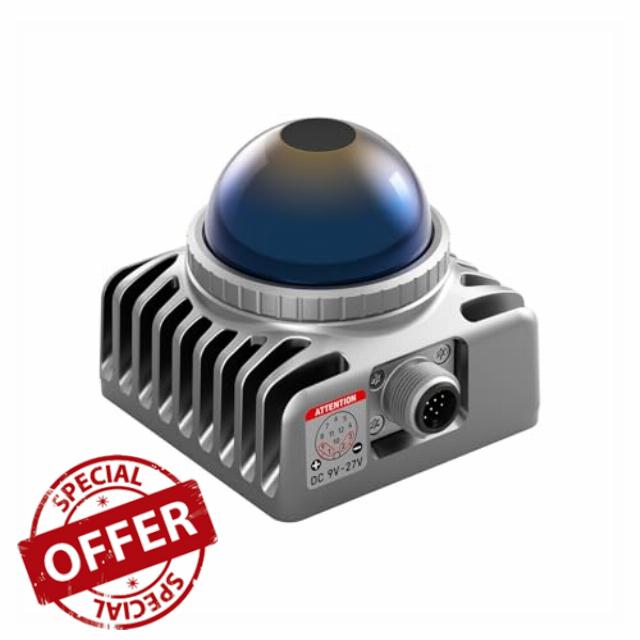
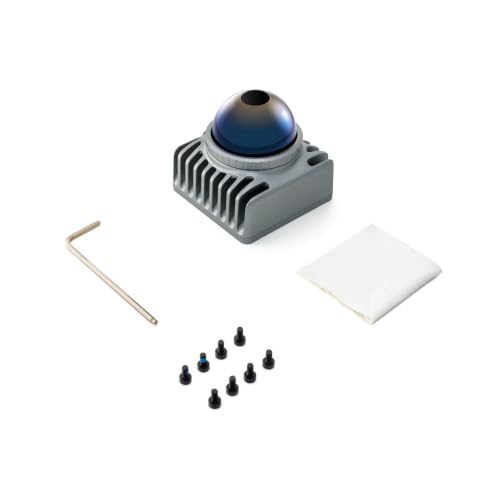
Livox Mid-360S 3D LiDAR Sensor – Successor to Mid-360, 360°×59° FOV, 0.1 m Blind Zone, 200 K pts/s, Built-in IMU, IP67 – Hybrid Solid-State LiDAR for AMR/AGV/SLAM(Without Connector)
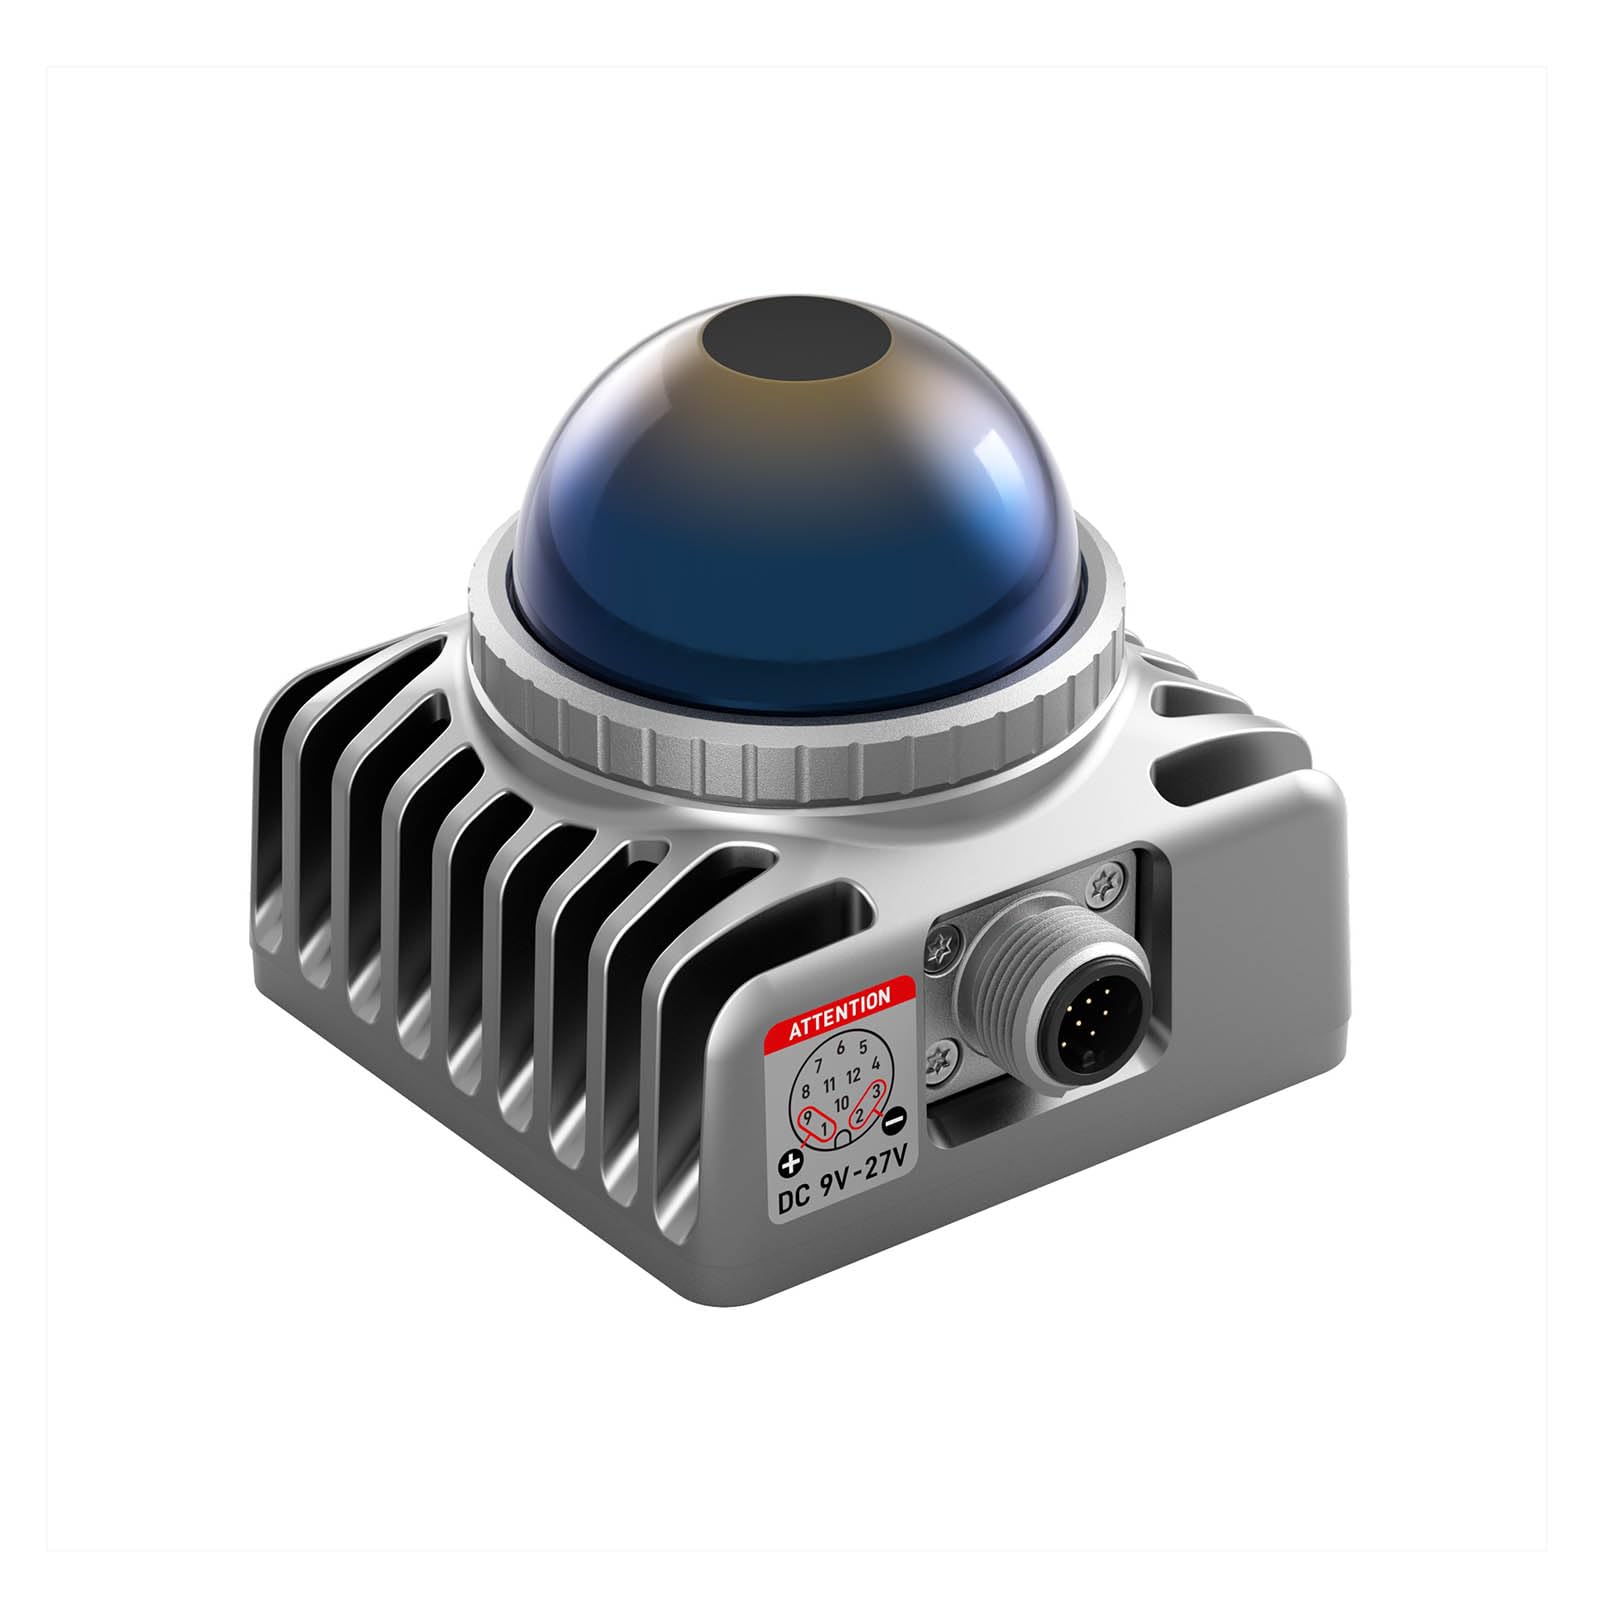
The Livox Mid-360S is the official successor to the widely deployed Mid-360, refined for AMR / AGV / service robot / logistics forklift / handheld mapping use cases. It keeps the class-leading 360°×59° FOV in a 265 g cube, while upgrading connector layout, scan-mode flexibility, and multi-unit anti-interference behavior.
If you’re expanding an existing Mid-360 fleet or starting a new low-speed autonomy project, Mid-360S is the current active SKU—Livox SDK / ros_driver2 optimizations now land on S first, and the original Mid-360 is being phased out.
Parameters (Mid-360S / vs Mid-360 same unless noted)
Laser: 905 nm, Class 1 (IEC 60825-1:2014)
Range: ≥38 m @10% refl / 100 m max @80% refl (original: 40 m @10% / 70 m @80%)
Blind zone: 0.1 m
FOV: 360° (H) × –7°~52° (V)
Points: 200 K/s | Frame: 10 Hz
Scan: Non-repetitive + Repetitive (S exclusive)
IMU: ICM-40609 | Sync: PTPv2 / GPS
Interface: 100BASE-TX Ethernet
Power: 6.5 W avg | 9–27 V DC
IP67 | –20 °C ~ 55 °C
Size / weight: 65×65×60 mm / 265 g
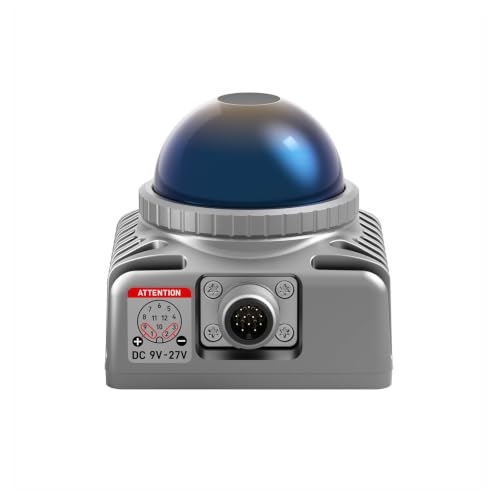
Connector: M12 aviation plug, recessed 2 mm + shifted 3 mm up vs Mid-360
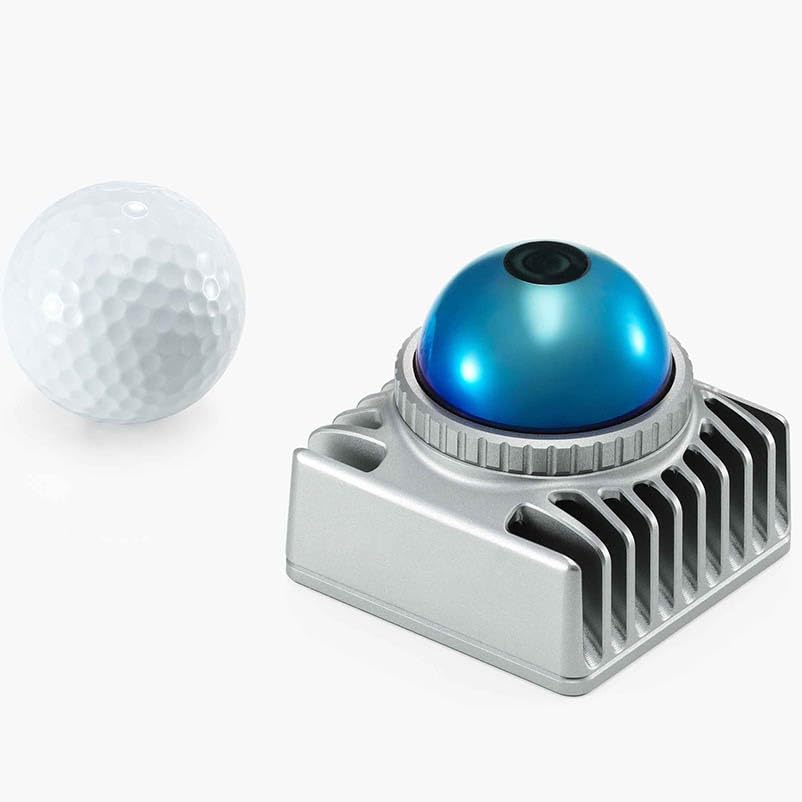
- 360° × 59° Ultra-Wide 3D FOV – Palm-Sized Full-Space Perception: Hybrid solid-state scanning delivers horizontal 360° + vertical –7°~52° (59°) in a 65×65×60 mm / 265 g cube. Enables low-speed mobile robots to perceive complex 3D environments and feed dense point clouds to SLAM & planning stacks—no more multi-LiDAR splicing.
- Mid-360S Exclusive: Dual Scan Mode (Repetitive + Non-Repetitive): Unlike the original Mid-360, the S standardizes repetitive scanning alongside non-repetitive, letting you switch per use case: repetitive for static HD mapping, non-repetitive for dynamic obstacle avoidance. Higher point-cloud utilization, cleaner SLAM input.
- 0.1 m Near Blind Zone + 200 K pts/s + Built-in IMU: ≤2 cm ranging precision @10 m, 200,000 pts/s @10 Hz, ICM-40609 IMU built-in with PTPv2 / GPS time sync over 100BASE-TX Ethernet. Minimum detection 0.1 m @10% reflectivity covers ground-level edges and dock approaches without dead zones.
- Redesigned M12 Connector & Stronger Anti-Interference – Cluster-Ready: S recedes the aviation-plug 2 mm inward + shifts 3 mm upward vs. Mid-360 for easier cable routing in compact chassis. Enhanced multi-LiDAR crosstalk immunity and stronger 100 kLux sunlight resistance make it fit for multi-robot fleets, warehouses, and outdoor–indoor mixed sites. Max range 100 m cutoff @80% reflectivity (≥38 m @10%).
- Drop-In Upgrade Path from Mid-360: Same mounting hole pattern and Ethernet interface as Mid-360—existing brackets and SDK/Livox ROS2 driver assets carry over. Works with Livox Viewer 2.5.0+ (low-frame-rate & low-RPM modes newly added). IP67, –20 °C ~ 55 °C, 9–27 V DC, 6.5 W avg.
| SKU: | B0H86N49R4 |
| Dimensions: | 7L x 7W x 6.5H centimetres |
| Brand: | ZICZNT |
| Manufacture: | Livox |